project · 2026-11-03
LPV model predictive control in C++
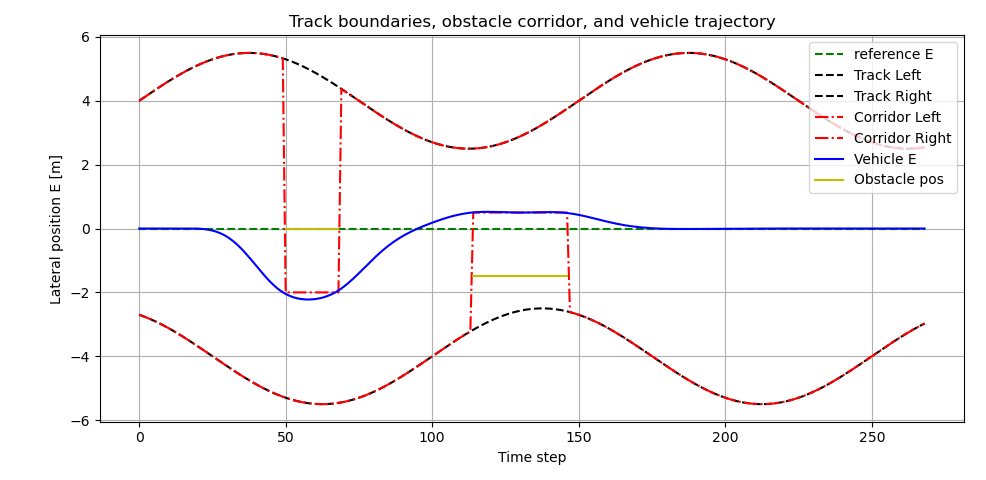
An open-source implementation with CasADi and IPOPT, illustrated by track and control-signal figures.
LPV_MPC_cpp explores linear parameter-varying model predictive control in C++. The public repository contains implementation code and example visualisations.